PID
🟠 Updated over a year agoPreview
📋 About This Mod
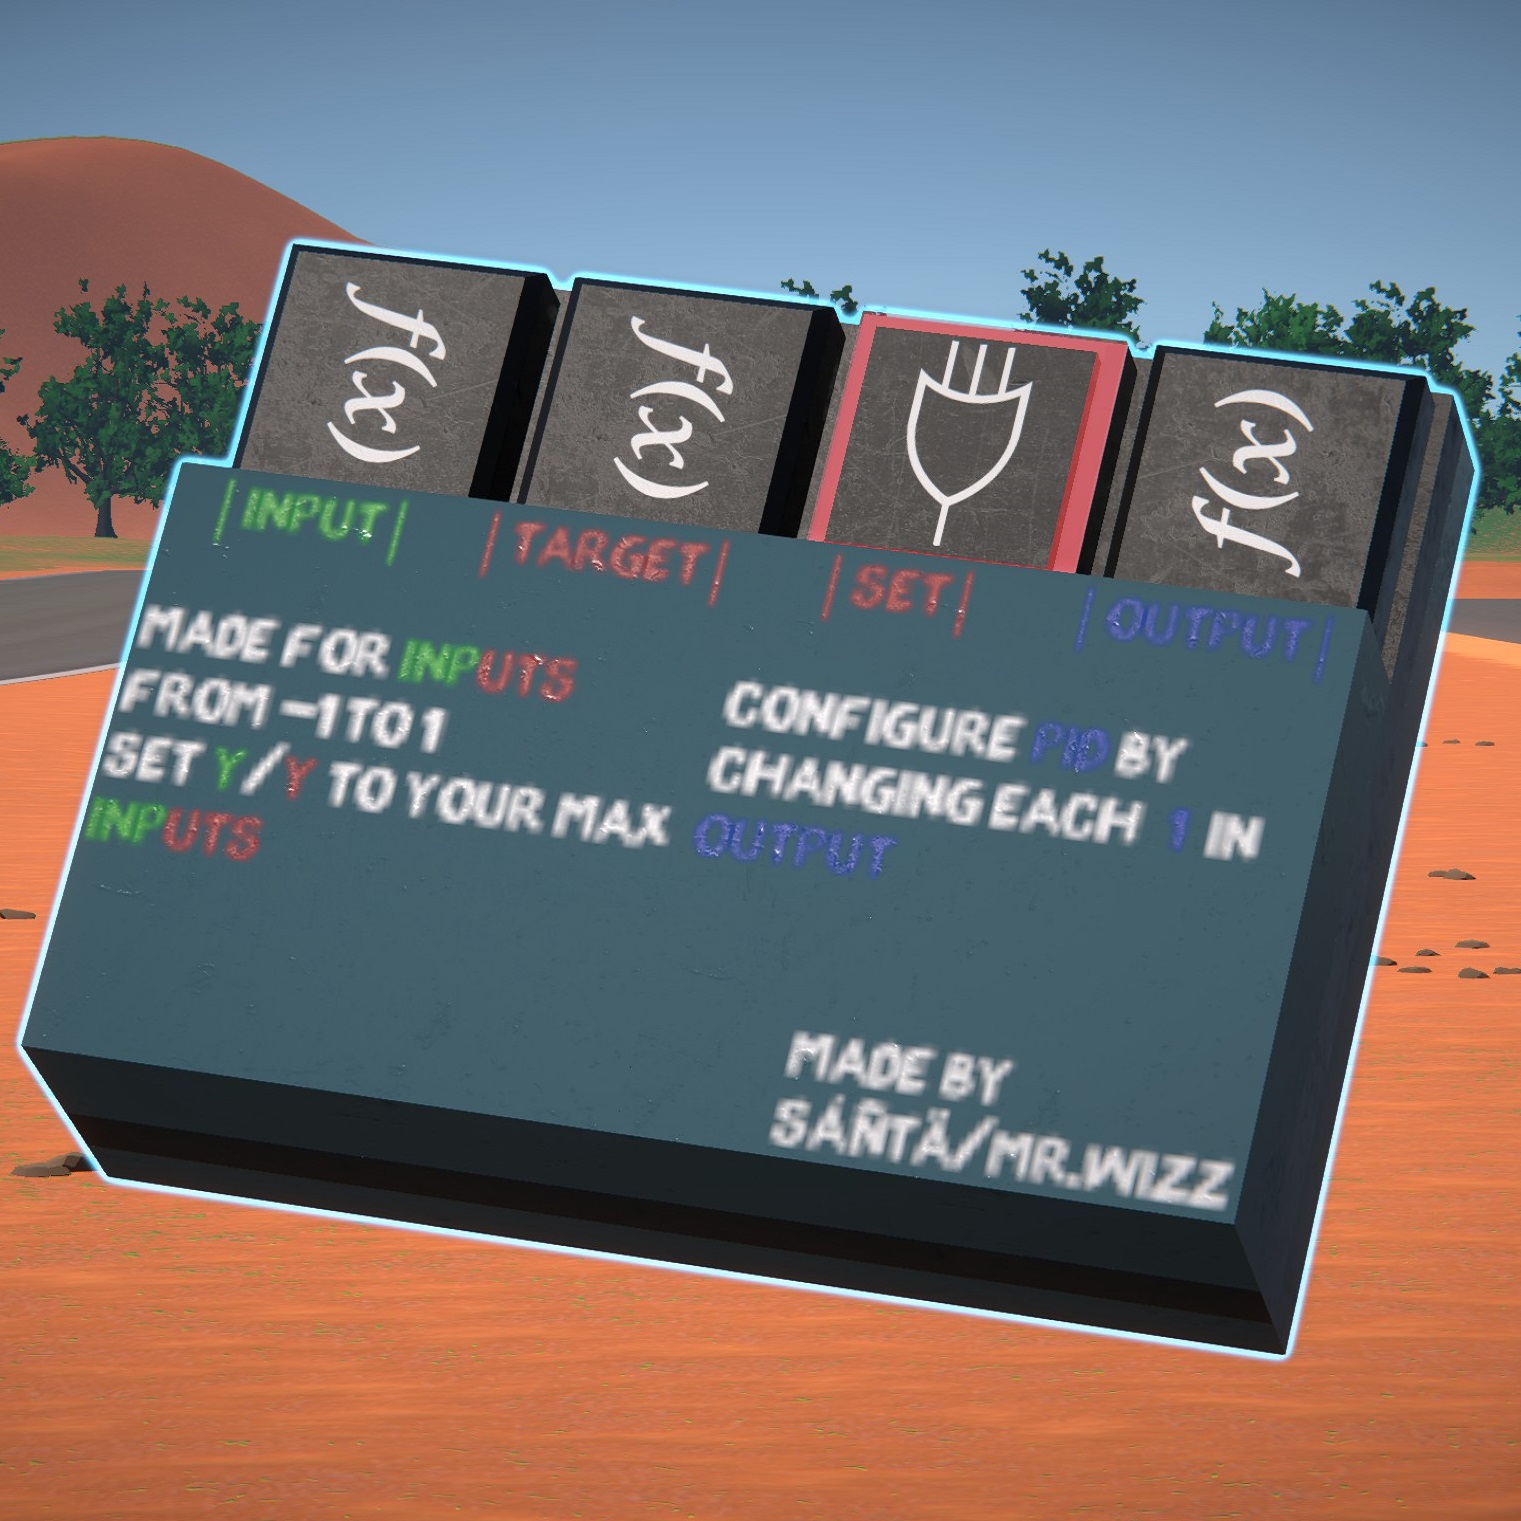
Proportional Integral Derivative Proportional (P): Reacts to the current error. Integral (I): Reacts to the accumulation of past errors. Derivative (D): Predicts future error based on its rate of change. Automatically predicts overshoot and maintains target output. Input/ Target: The PID works best on -1 to 1 input, so in the boxes you can divide X by your max known input and the controll loop will function optimally. Set: Your target value is taken from the target box, changed it from the input box for easier implementation. Output: The output is where you callibrate the PID, the 1s represent the gain for each function aka their influence on the output. Alot goes into tuning a pid so i suggest trial and error or watching a tutorial. The output outputs a momentary number built to shift a normal mode linear actuator but should also work fine on engines and servos. The demo supplied can help you understand the influence of the different functions. Time to build and tune was around 20 hours. (updated to make it easier to implement, now has separate input and target boxes)
📊 Mod Details
- Game
- Gearblocks Mods
- Author
- 76561198119967936
- Version
- N/A
- Downloads
- 70
- Endorsements
- 0
- Category
- drone, plane, logic, update, circuit, pid, proportional, integral, derivative, controll, math
- Created
- 10/4/2025
- Updated
- 10/5/2025
🔧 How to Install GearBlocks Mods
Subscribe on Steam Workshop. Mods auto-download and install. Launch the game to activate.
📖 Full step-by-step install guide for GearBlocks →
Visit the official mod page for specific installation instructions for this mod.
🎮 Need cheat codes or console commands? Check ur gaming wiki for GearBlocks commands, item IDs, and more.
Keep browsing — more GearBlocks mods await